
- VizTool meeting – notes @ requirements page…
- working on Dynamic Panel – done!
- checked in as DynamicPanel Flex Component project
- continue working on FA4
- incorporating the new Dynamic Panel
Phil 8.14.13
8:00 – 11:00 SR
- Backups
- Some more back and forth with Brandon W. Not sure where that’s going.
- Showed Pat VISIBILITY. She might be able to help with a proof-of-concept ROI visualization
- Poked at Dong’s dynamic panel problem
11:00 – 4:00 FP
- Added force interaction between gripper and target sphere
- Determined how to make the ratio calculation work. If the sum of all of the magnitudes on the target is greater than zero, then the ratio equals the magnitude of the sum of the force vectors divided by the sum of each magnitude. A value of 1.0 means that there is no contact. A value of 0.0 is a perfectly opposing contact. As currently implemented, if the ratio is less than 0.5, then the position of the target sphere is set to the point that lies between the two grippers, otherwise the (summed) contact force vector is applied to the target.
- Need to add walls around the work environment so that the targets can’t get out of reach.
- Need to add the metal standoffs for the speakers. I was thinking about ordering some box tubing, but the sizes weren’t optimal. I’ll bend up some metal tonight.
- Need to start adding in the code that will support the experiments
- Task code
- Feedback options
- Position and pressure only
- Position, force feedback and pressure
- Position, pressure and vibration
- Position, force feedback, pressure and vibration.
Dong Shin 08.14.2013
- continue working on FA4
- it looks like everything has been converted…
- testing!
- DynamicPanel acting weird – components on upper right corner not getting clicked, events get to TitleBar instead…
- rewriting DynamicPanel using spark skins…..
Phil 8.13.13
8:00 – 10:00 SR
- Backups
- There may be a problem where some of the data is disappearing after being entered in the VizTool? Overheard a conversation, but didn’t follow up.
10:00 – 4:30 FP
- Got the wiring cleaned up.
- Integrating collision response with the targetSphere. The math is looking reasonably good.
- Added multi-target capability.
- Added adjustable sensitivity to the pressure sensors. The pushing directly on the speakers is causing artifacts. I think I need to build small c-section angle that decouples the squeezing force from the Vibroacoustic feedback.
Dong Shin 08.13.2013
- continue working on FA4
- adding QueryBuilder
Phil 8.12.13
8:00 – 10:30 SR
- Backups
- Set up new workstation
10:30 – 5:00 FP
- Brought in hot glue gun
- Working on constraint code. Got the framework done.
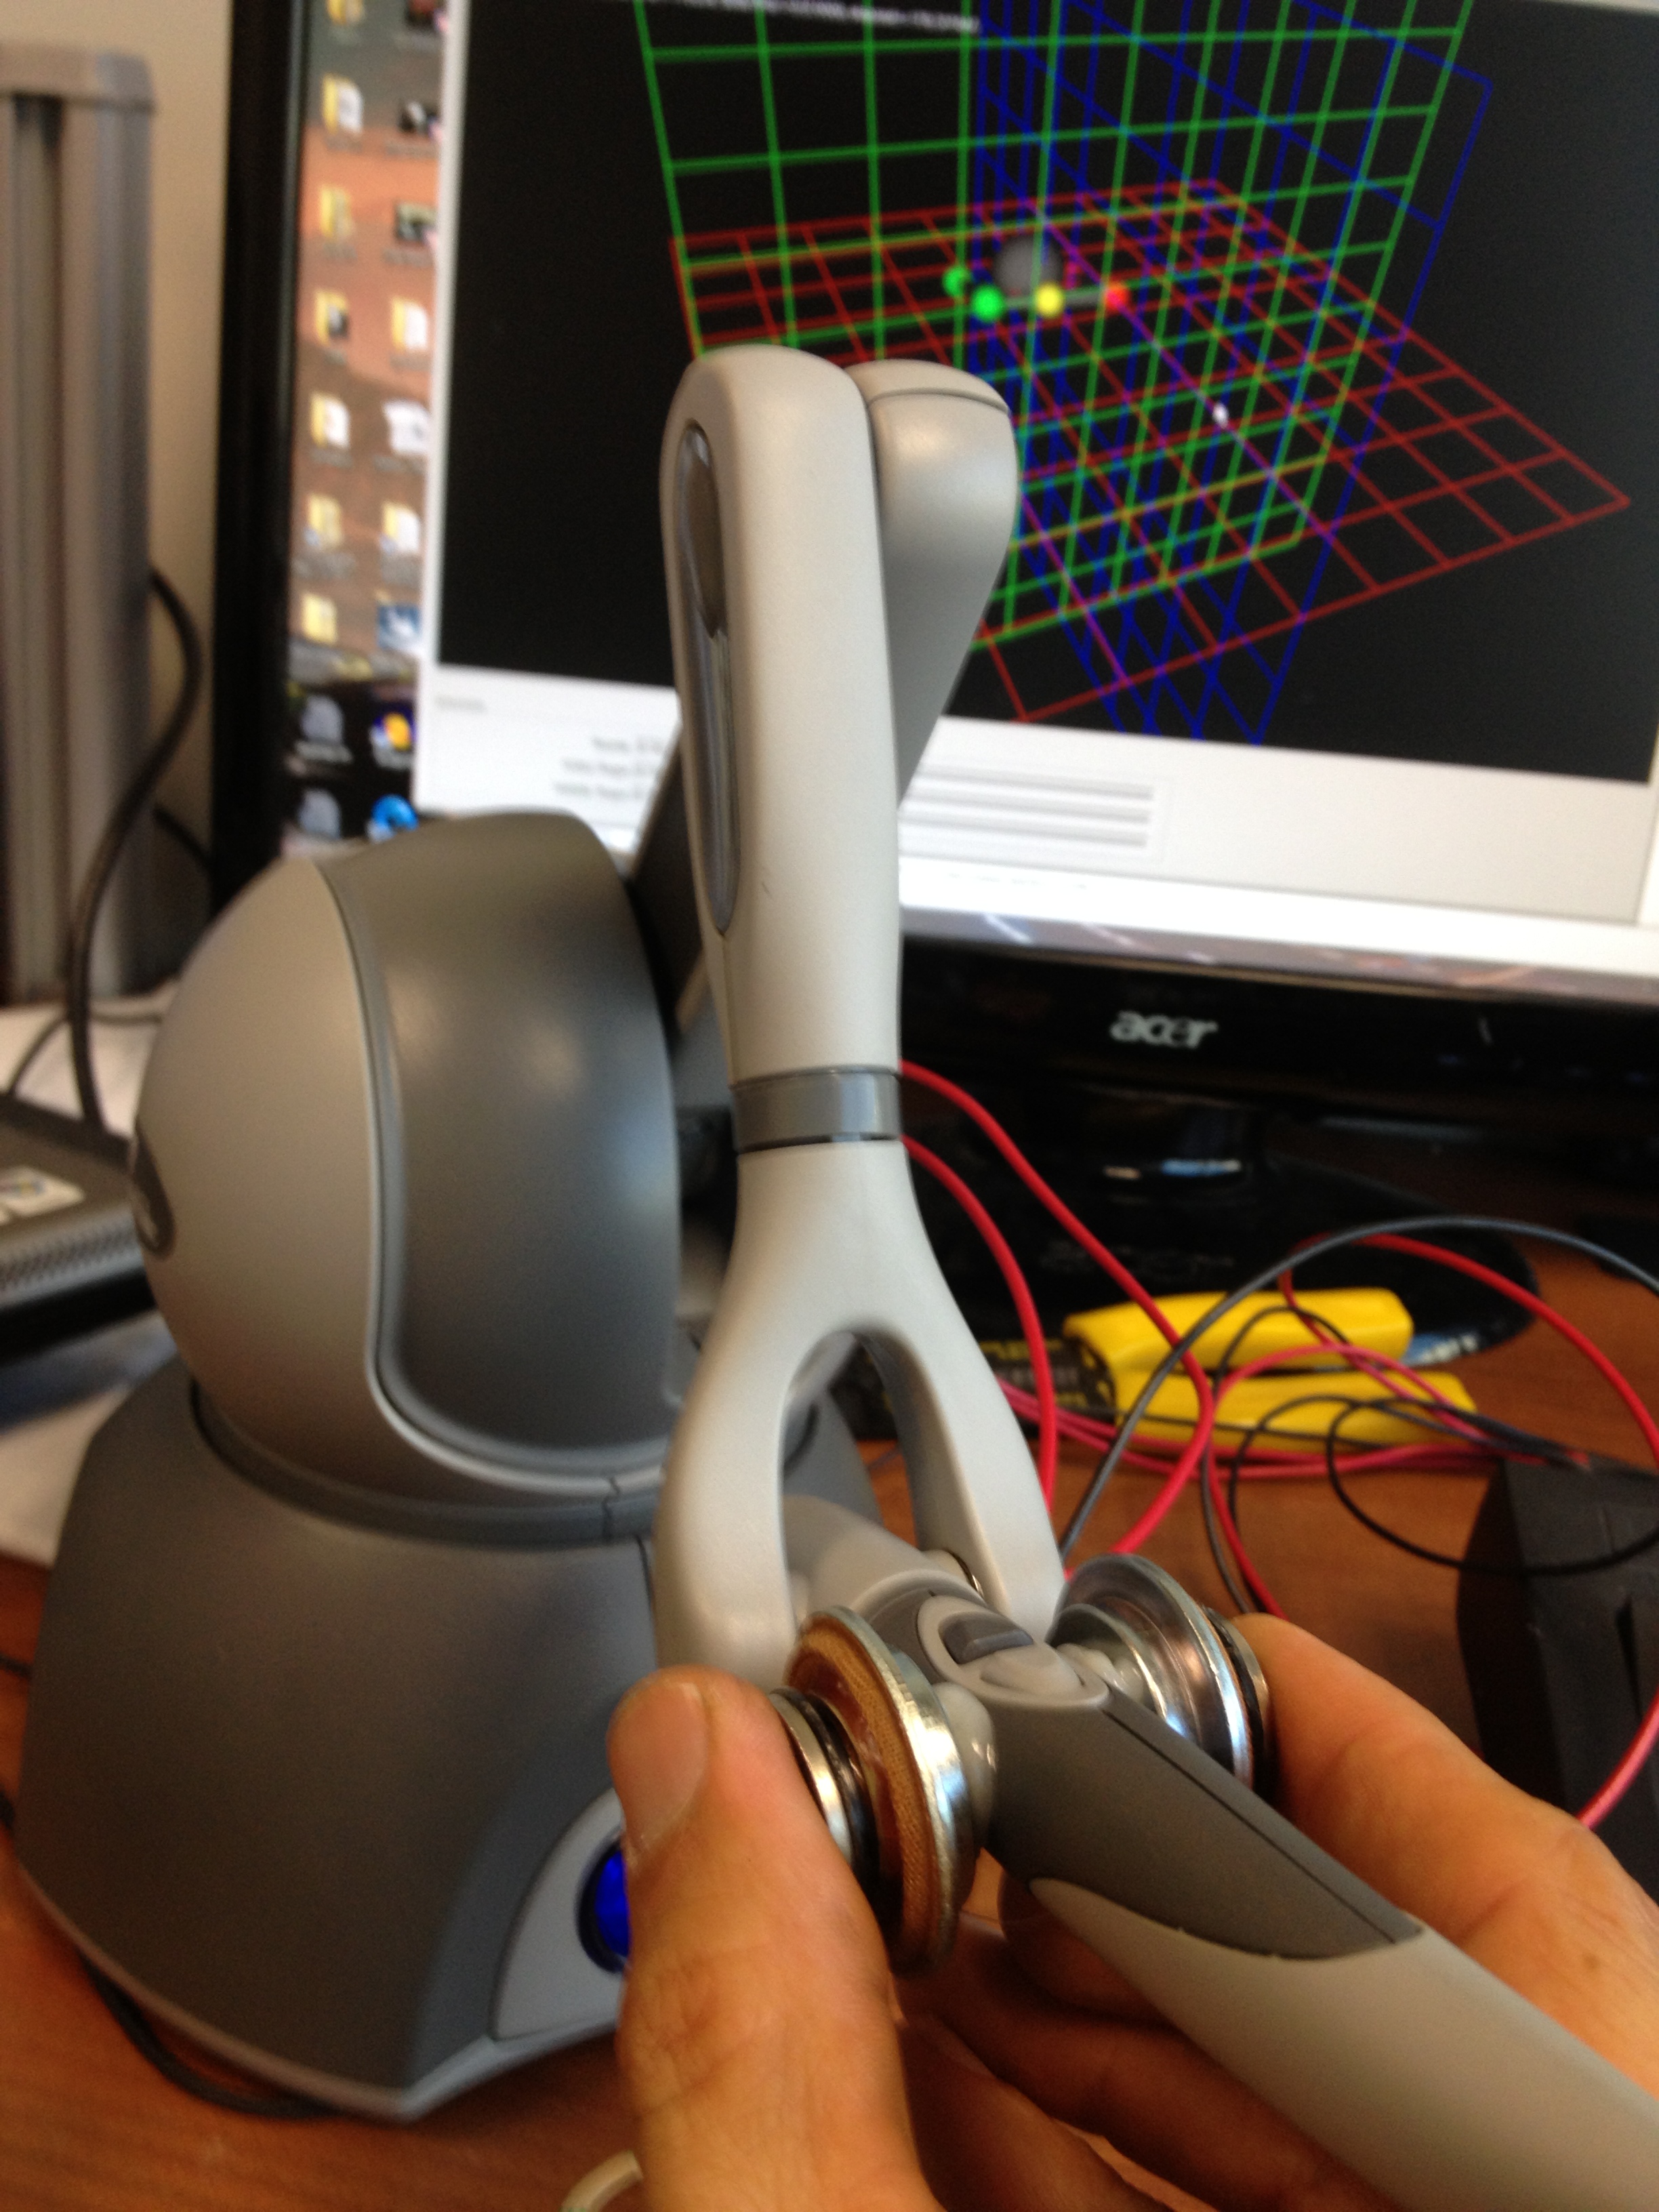
- Got the actuators mounted on the Phantom!
Dong Shin 08.12.2013
- converting FA to Flex 4.6
- working on Financial Data Editor – done
- flexlib 2.4 is not compatible – new 2.5 version
- arc90 flexlib.container (CollapsiblePanel) is not compatible – looking for suitable replacement….
- trying ShinyLib CollapsiblePanel
- not working!
- trying http://store.kapit.biz/media/demo/klovis/prod/index.html#/Panel
- converting all mx references to fx….
- States not compatible! (LoginScreen) – removed for now.
Phil 8.9.13
8:00 – 10:00 SR
- Backups
- Desk issues
- Looks like someone might be interested in Visibility pretty much out of the blue. We’ll see
10:00 – 5:00 FP
- Wired up the speakers to the old grip interface. Amp and speakers work nicely
- Now to work on the force moving the gripper.
- I also need to get the target force vector back so that I know how to move the target. Not looking forward to implementing friction…
- Hmm. Before I commit to doing it right, I’m wondering if I can look at the summed magnitude of the force vectors vs the magnitude of the summed force vectors. If the first is high and the second is low, then it means that the ball is being squeezed. Above a certain ratio, The target could simply be at the center of the sensor points.
- Assuming that the above will work, I need to do the following to targets
- An awareness of a “floor” that provides either a limit to motion or an upward force once penetrated
- An awareness of the forces being applied and the sources of the forces. Since these are spheres with given radius, the information to be tracked could be as simple as the center positions of the items
- Gravity and mass?
Dong Shin 08.09.2013
- converting FA to Flex 4.6
- ProjectMgmt is done
- working on ProjectEditor – done
- fixed titleIcon overlapping with title in dynamicPanel
- working on FinancialDataEditor
Phil 8.8.13
8:00 – 10:00 SR
- Backups
- Deployed new FA, which seems to be working well
- Met Pat.
10:00 – 5:00 FP
- Building a two-fingered gripper
- Going to add sound class to SimpleSphere so that we know what sounds are coming from what collision. Didn’t do that’ but I’m associating the sounds by index, which is good enough for now
- Need to calculate individual forces for each sphere in the Phantom and return them. Done. To keep the oscillations at a minimum, I’m passing the offsets from the origin. That way the loop uses the device position as the basis for calculations within the haptic loop.
- Here’s the result of today’s work:
Dong Shin 08.08.2013
- deployed new FA
- ingest COGNOS works!
- found Advanced Query not working properly when Select All is clicked – fixed
Phil 8.7.13
8:00 – 11:30 SR
- Backups
- Training
11:30 – 4:00 FP
- Basically spent the whole day figuring out how the 4×4 phantom matrix equates to the rendering matrix (I would have said OpenGL, but that’s not true anymore. I am using the lovely math libraries from the OpenGL SuperBible 5th Edition, which makes it kinda look like the OGL of Yore. Initially I thought I’d just use the vector components of the rotation 3×3 from the Phantom to get the orientation of the tip, but for some reason, parts of the matrix appear inverted. So instead of using them directly, I multiply the modelviewmatrix by the phantom matrix, Amazingly, this works perfectly. To make sure that this works, I rendered a sphere at the +X, +Y and +Z axis in the local coordinate frame. Everything tracks. So now I can create my gripper class and get the positions of the end effectors from the class. And since the position is in the global coordinate frame, it kind of comes along for free,
- Here’s a picture of everything working:
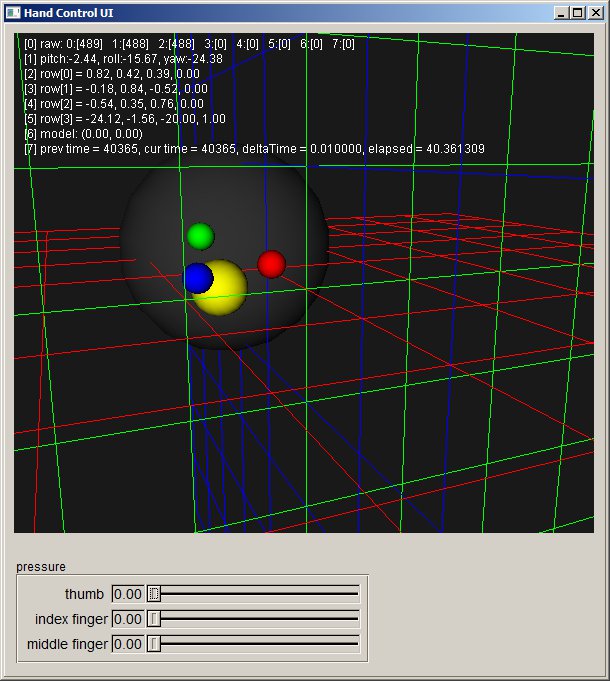
- Tomorrow, I’ll build the gripper class and start feeding that to the Phantom. THe issue will be to sum the force vectors from all the end effectors in a reasonable way.
Dong Shin 08.07.2013
- continue working on FA
- removed COGNOS conflict resolution
- started migrating FA to Flex 4.6 – panels and canvases behave better!
Dong Shin 08.06.2013
- group meeting at R&E
- talked with Lenny about the duplicate COGNOS Contract – no need to keep old data
- continue working on FA
- remove old COGNOS data on new import
- fixed sum of the dollars not working for some data (NULL contracts)
- more tooltips!
Phil 8.6.13
8:00 – 11:00 SR
- Backups
- Group meeting
- Spent some time chasing down the duplicated bug. The decision is to truncate the contracts_cognos table before ingest. There is still a problem where multiple rows are not being summed even though they are claimed (where contract numbers are NULL)
11:00 – 4:00 FP
- Integrating all the pieces into one test platform. The test could be to move a collection of physically-based spheres (easy collision detect) from one area to another. Time would be recorded from the indication of a start and stop (spacebar, something in the sim, etc). Variations would be:
- Open loop: Measure position and pressure, but no feedback
- Force Feedback (Phantom) only
- Vibrotactile feedback only
- Both feedbacks
- Probably only use two actuators for the simplicity of the test rig. It would bean that I could use the laptop’s headphone output. Need to test this by wiring up the actuators to a micro stereo plug. Radio Shack tonight.
- Got two-way communication running between Phantom and sim.
- Have force magnitude adjusting a volume.
- Added a SimpleSphere class for most of the testing.
 viztales

You must be logged in to post a comment.